Collaborative Robots
Power and force limited collaborative arms designed for human-robot shared workspaces.
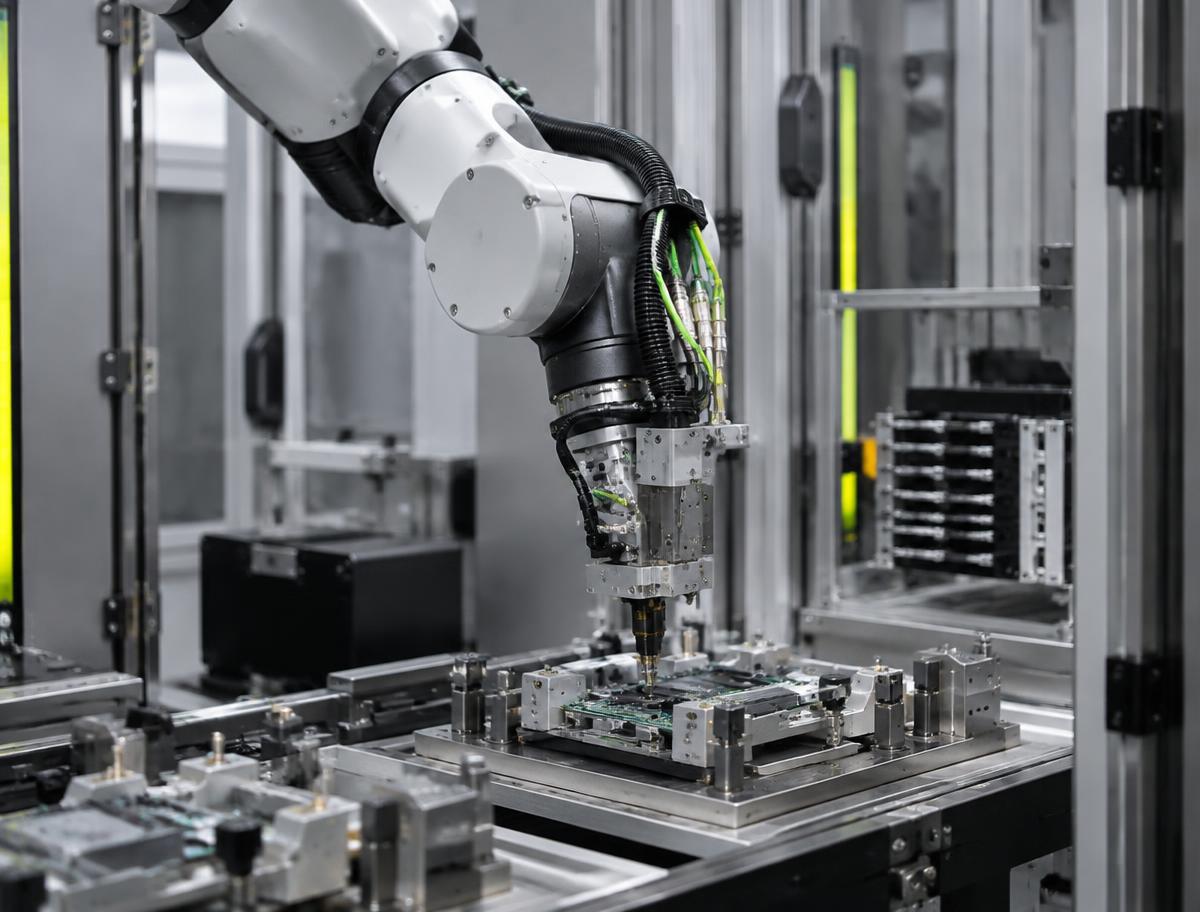
Collaborative Robots (Cobots) feature rounded ergonomic profiles, lightweight aluminum alloy links, and sensitive joint torque sensors that automatically halt motion upon detecting human contact (ISO/TS 15066 compliance). They eliminate the need for bulky safety cages, allowing operators and robots to work together on the same production line.
Architecture & Capabilities
Key Engineering Features
- Sensitive joint-level torque sensors detecting minor contact forces (<50 N)
- Intuitive hand-guiding lead-through programming — teach points by moving the arm by hand
- Safety certified to ISO 10218-1 and ISO/TS 15066 (PLe / Cat 3)
- Lightweight structure easily relocated on mobile cart bases
- Open API and ROS support for agile prototyping and software integration
Control & Mechanical Integration
Simple single-phase 110V/230V power connection. Direct network integration with industrial protocols and mobile robot bases.
Technical Data
Performance Ratings
| Engineering Parameter | Standard Value |
|---|---|
| Rated Torque / Force | [Specification available on request] |
| Maximum Speed | [Specification available on request] |
| Rated Payload | [Specification available on request] |
| Accuracy / Repeatability | [Specification available on request] |
| Operating Voltage | [Specification available on request] |
| Communication Protocol | [Specification available on request] |
| Protection Rating (IP) | [Specification available on request] |
| Operating Temperature | [Specification available on request] |
Custom gear ratios, specialized hollow-bore diameters, and customized motor windings are available upon technical review with our design team.
Expedited Inquiry
Enquire About Collaborative Robots
Connect directly with our application engineers for sizing verification, mechanical availability, and quantity pricing.
Collaborative Robots (Robotic Arms)
Connected Ecosystem
Related Technologies for Collaborative Robots
Complementary Products
- 4-Axis RobotsRobotic Arms
Four-axis robots (such as SCARA and Cartesian architectures) feature rigid arm links operating in the horizontal X-Y plane with a dedicated vertical Z-axis quill and rotational theta axis. Ideal for rapid assembly, component insertion, and high-cadence pick-and-place operations where parts remain parallel to the work surface.
- 6-Axis RobotsRobotic Arms
The 6-Axis Robotic Arm coordinates six articulated rotary joints, allowing end-of-arm tooling to achieve any commanded position (X, Y, Z) and orientation (Roll, Pitch, Yaw) within its spherical reach envelope. Essential for contoured welding, 3D laser cutting, machine tending, and multi-angle component assembly.
- Pick & Place RobotsRobotic Arms
Pick & Place Delta Robots utilize a parallel kinematic structure consisting of three lightweight carbon fiber arm linkages connected to a common base. Because the heavy servo motors remain stationary on the overhead base frame, the moving end-effector has minimal inertia, allowing extreme accelerations up to 15 G.
Applicable Industries
- Collaborative Assembly & Screwdriving
Robotic integration for Collaborative Assembly & Screwdriving manufacturing environments.
- End-of-Line Palletizing
Robotic integration for End-of-Line Palletizing manufacturing environments.
- Quality Inspection & Testing
Robotic integration for Quality Inspection & Testing manufacturing environments.
- Lab Automation & Pipetting
Robotic integration for Lab Automation & Pipetting manufacturing environments.